

Robot Programming Library
program smarter. deploy faster
The Kawasaki Robotics AS Library provides a growing collection of pre-configured AS programming modules, reusable code templates and engineering resources that help you implement common robot functions faster, more consistently and with less programming effort.
Save Engineering Time
- Start with ready-made programming templates instead of creating standard routines from scratch.
Reduce Programming Effort
- Start from a working, documented routine instead of a blank program.
Improve Programming Consistency
- Reuse validated programming building blocks across projects and engineering teams.
Standardize Best Practices
- Ensure common programming standards throughout your organization.
Accelerate Commissioning
- Reduce development time and focus engineering resources on application-specific challenges.
Simplify Knowledge Sharing
- Access documentation, examples and reusable code from one centralized platform.
Engineering Time Is Valuable
Programming the same standard robot functions again and again costs valuable engineering time. Whether you’re implementing standard pick-and-place routines, movement commands or common automation tasks, repetitive programming increases project costs and extends commissioning time.
The Kawasaki Robotics AS Library helps eliminate this repetitive work by providing a centralized collection of reusable, validated programming templates and engineering resources.
What is the AS Library?
The AS Library is a desktop application designed for Kawasaki robot programmers and commissioning engineers. It combines reusable AS programming templates, project documentation and an integrated code generator in one easy-to-use interface, enabling teams to standardize programming across projects and locations.
What’s in Every Module?
Documentation
Every routine comes explained: what it does, which task it belongs on, every parameter, and the limits you need to know.
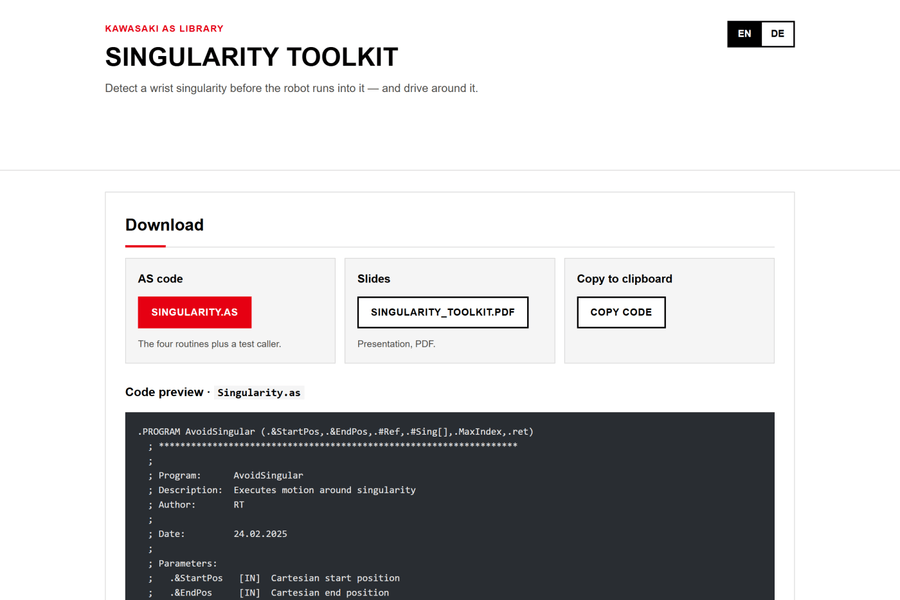
Ready-to-run AS Code
Download the AS file, read it before you do, and load it onto the controller. No conversion, no licence, no tooling in between.
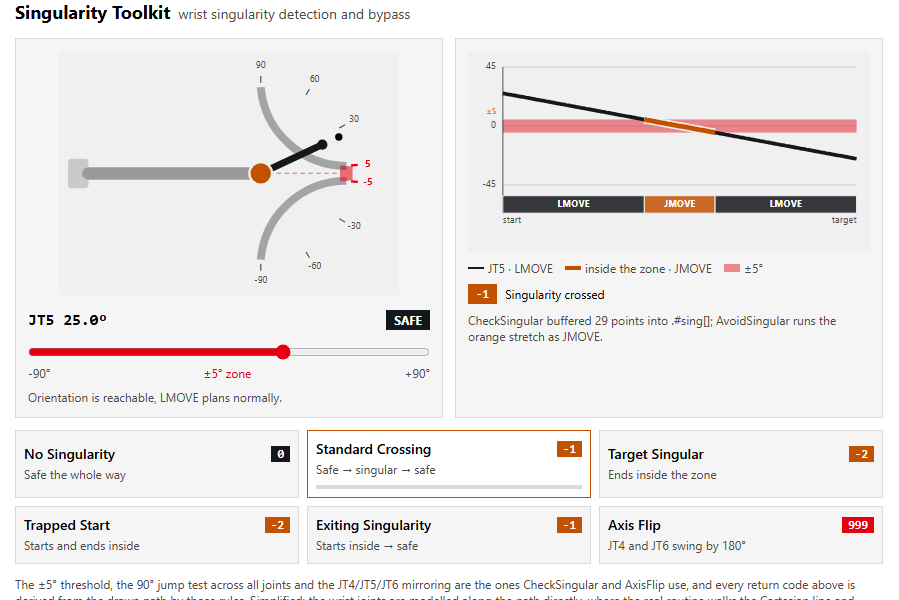
Interactive Visualisations
Visual explanations – interactive graphics that make the concepts easier to grasp than text alone.
how does it work?
Go from command to robot code in 3 simple steps:
- Browse the command categories and choose the AS command template for your needs.
- Fill in movement parameters and set conditions and options.
- Preview generated AS code and then copy or export to a file.
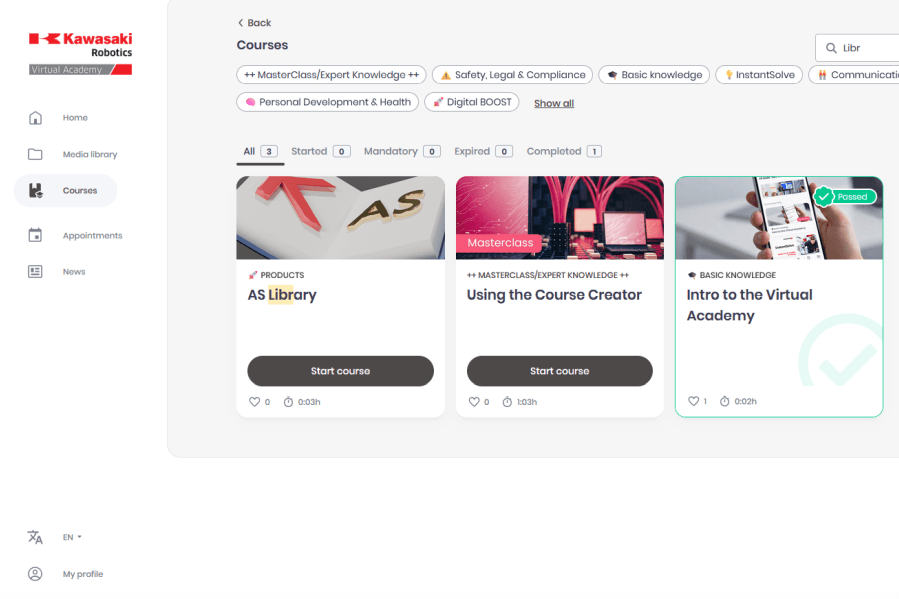
Pick a Module
Browse the AS Library modules on the Academy and open the one that matches your task.
Understand it
Work through the documentation -what runs on which task, what each parameter does, where the limits are.
Download and Adapt
Download the AS file, adjust the variables to your application, and load it onto the controller.
Example Modules
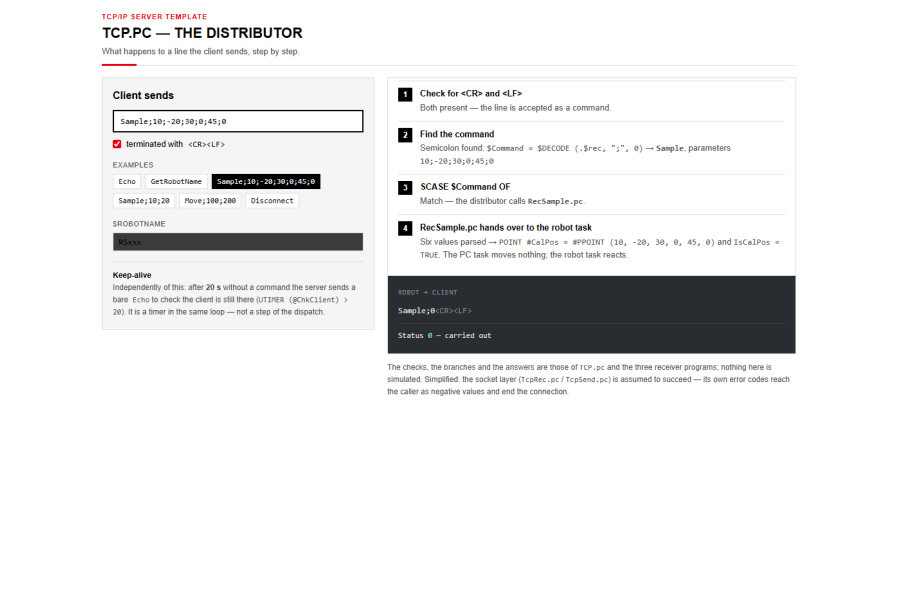
TCP/IP Server
Let a PC or PLC talk to the robot: a background server task with connection management, keep-alive and one handler per command – extend it with your own.
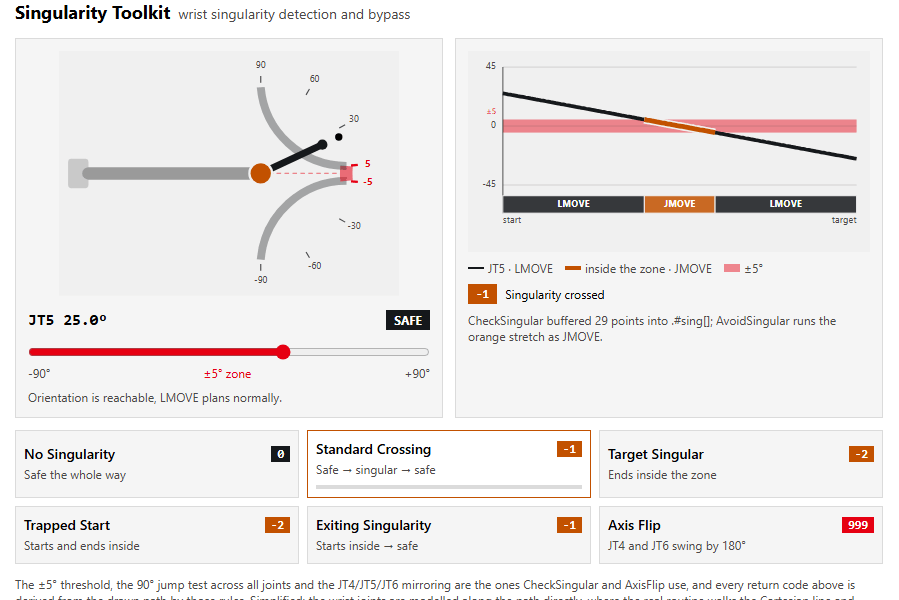
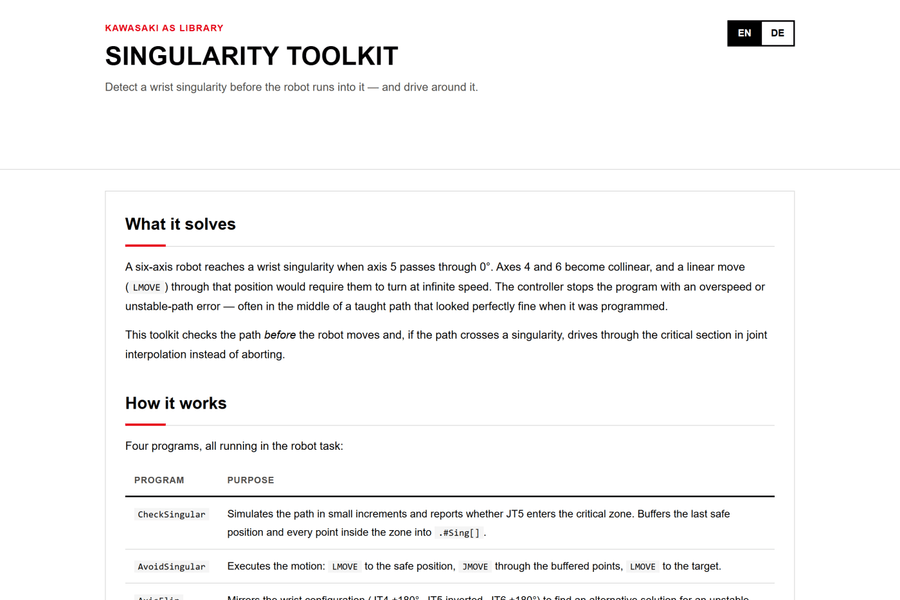
Singularity Toolkit
Detect a wrist singularity before the robot runs into it: the path is simulated in advance, the critical section is crossed in joint interpolation instead of aborting with an overspeed error.
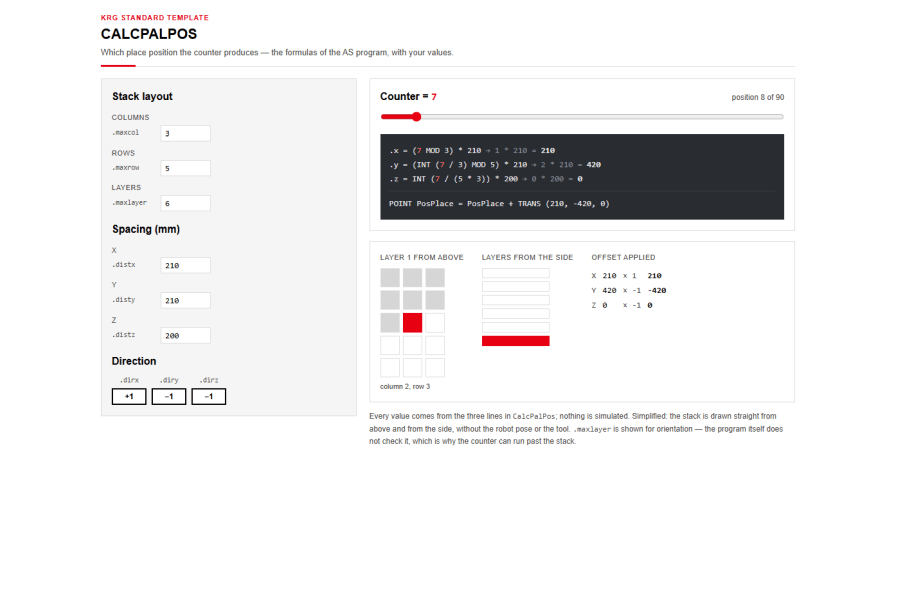
Kawasaki Robotics Standard Template
One program structure for every project: a defined entry point, safe initialisation and homing, a watchdog that restarts background tasks, and cycle time statistics built in.
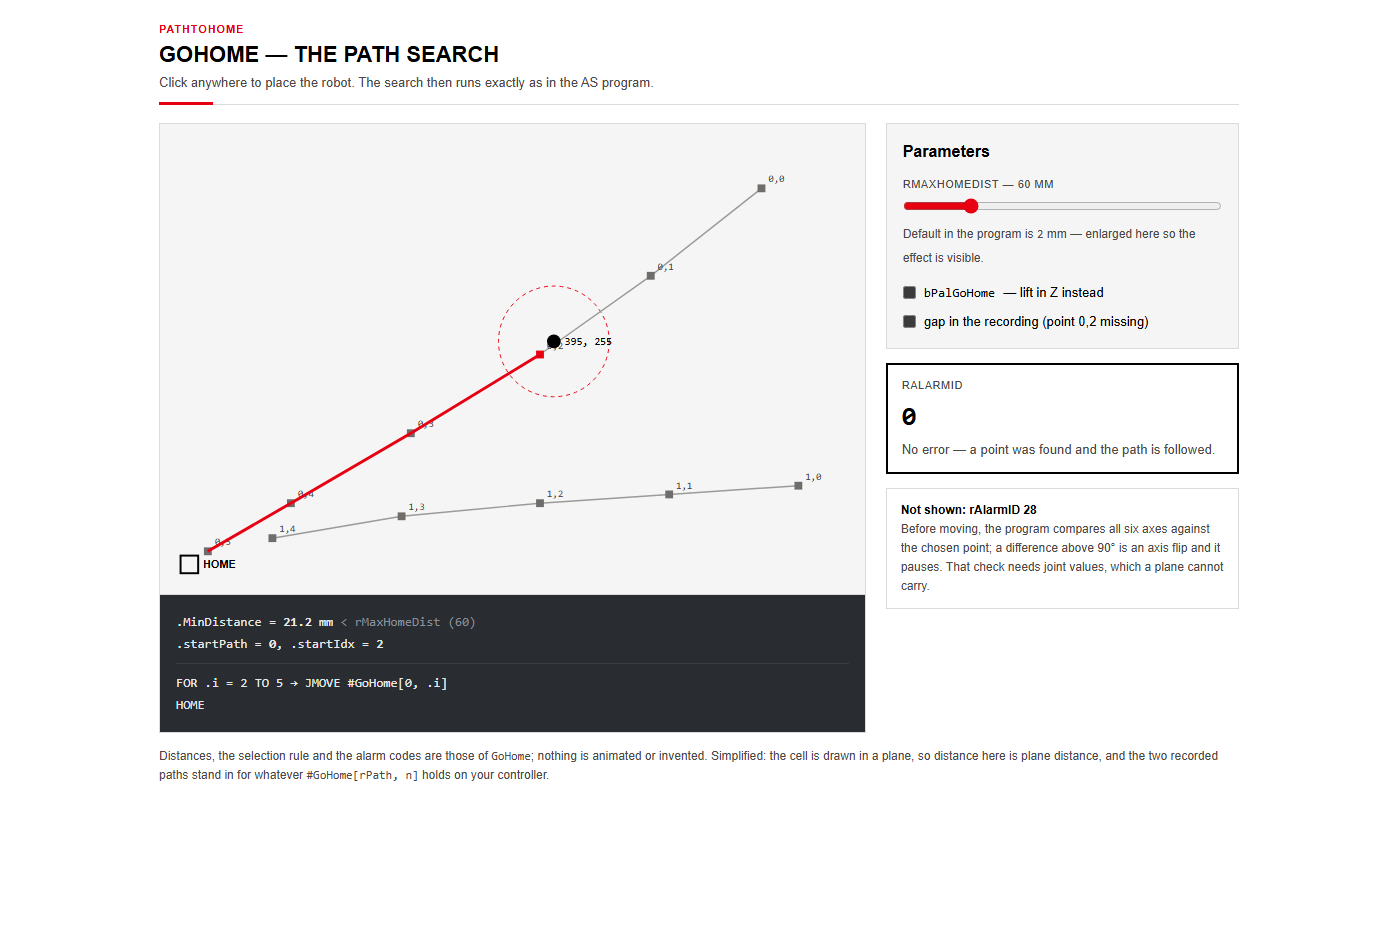
Safe Return to Home
Get the robot out of the cell without a collision: record the way in once, and the robot follows it back from wherever it stopped.
More modules are in preparation.
Start With a Routine That Already Works
Reduce repetitive programming tasks and accelerate robot integration with the Kawasaki Robotics AS Library.